Project context
The requirement behind the terminal.
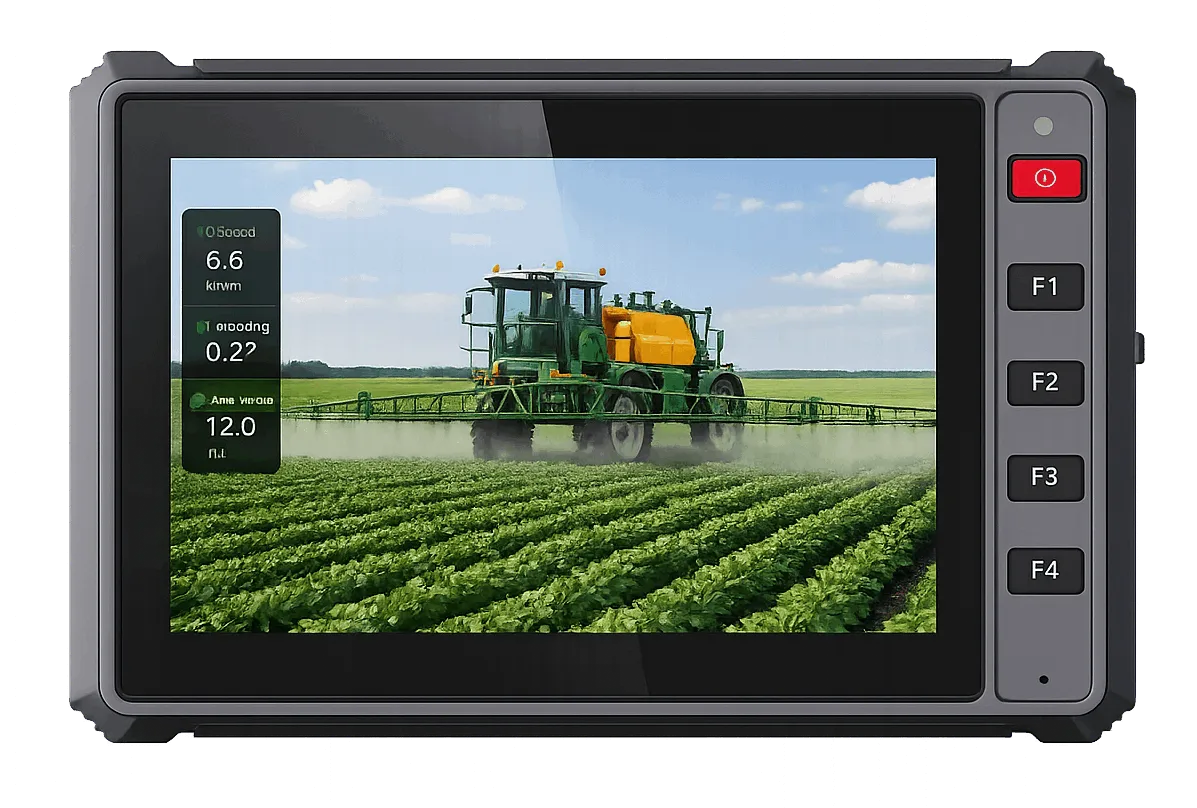
The equipment builder required one operator interface for task information, machine status and field visibility while preserving a clear boundary between the terminal, external sensors and the spraying-control system.
Role of the PDS platform
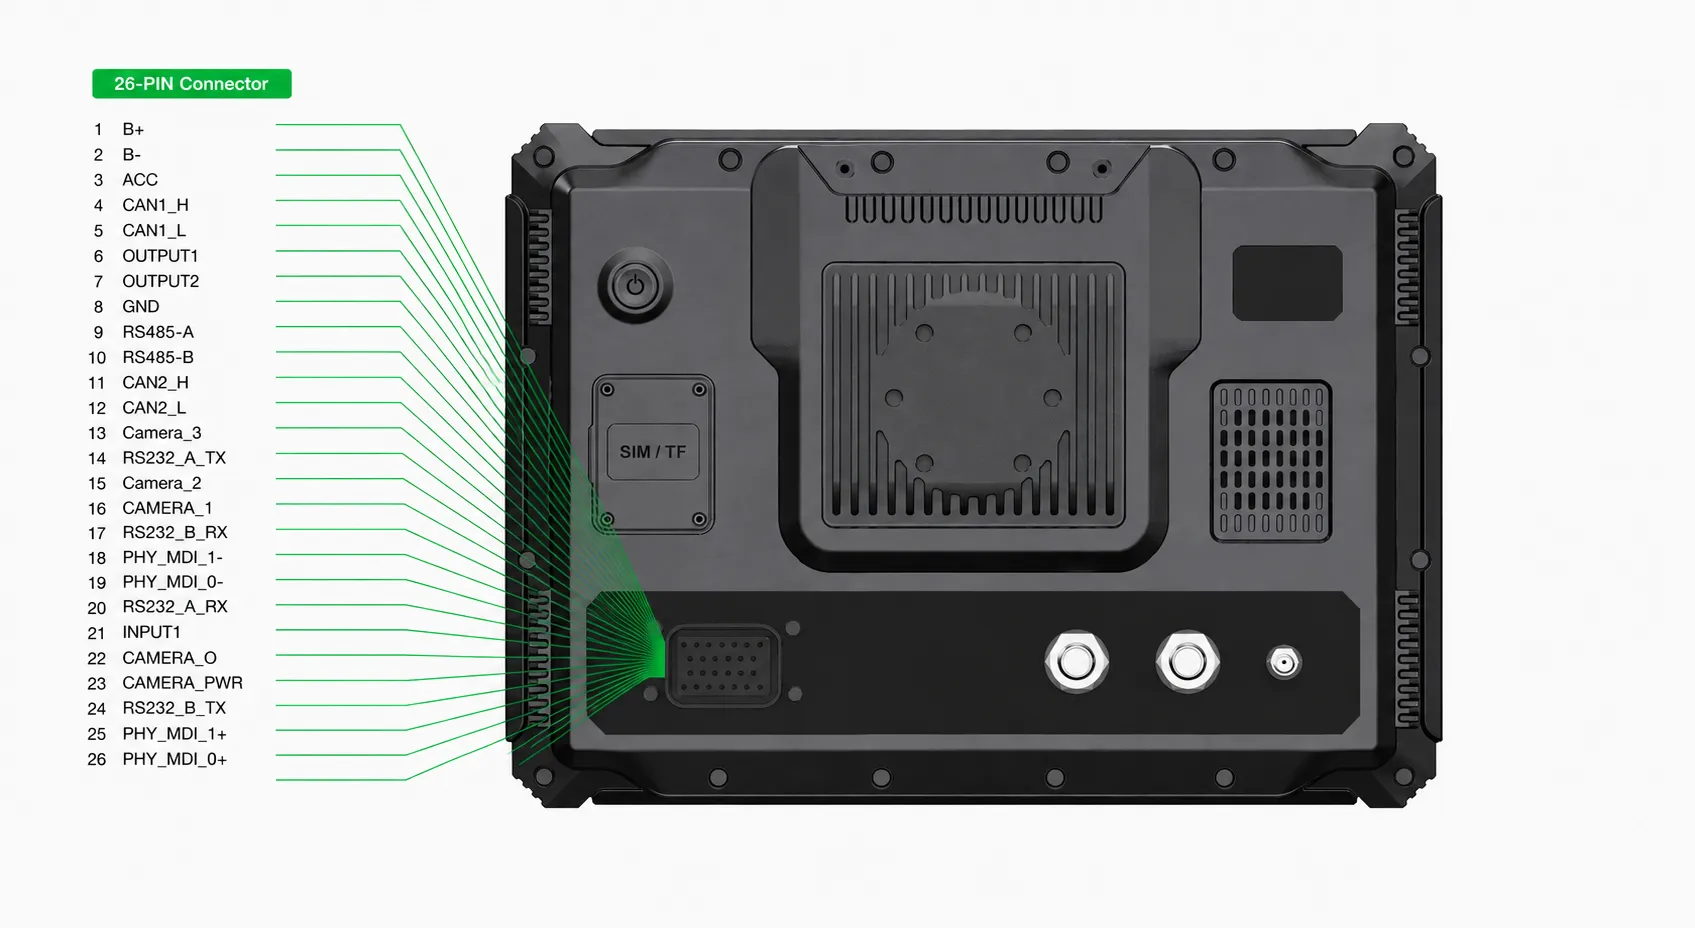
The published configuration used a T10 platform with Linux and Qt, vehicle interfaces, positioning inputs and camera connections. Final control logic and field acceptance remained project responsibilities.
What the PDS scope supplied
- 10.1-inch T10 vehicle-computer platform
- Linux and Qt application environment described by PDS
- CAN and serial interface path for project devices
- Camera and positioning integration starting point
What remained in the wider system
- Spraying-control algorithms and actuator authority
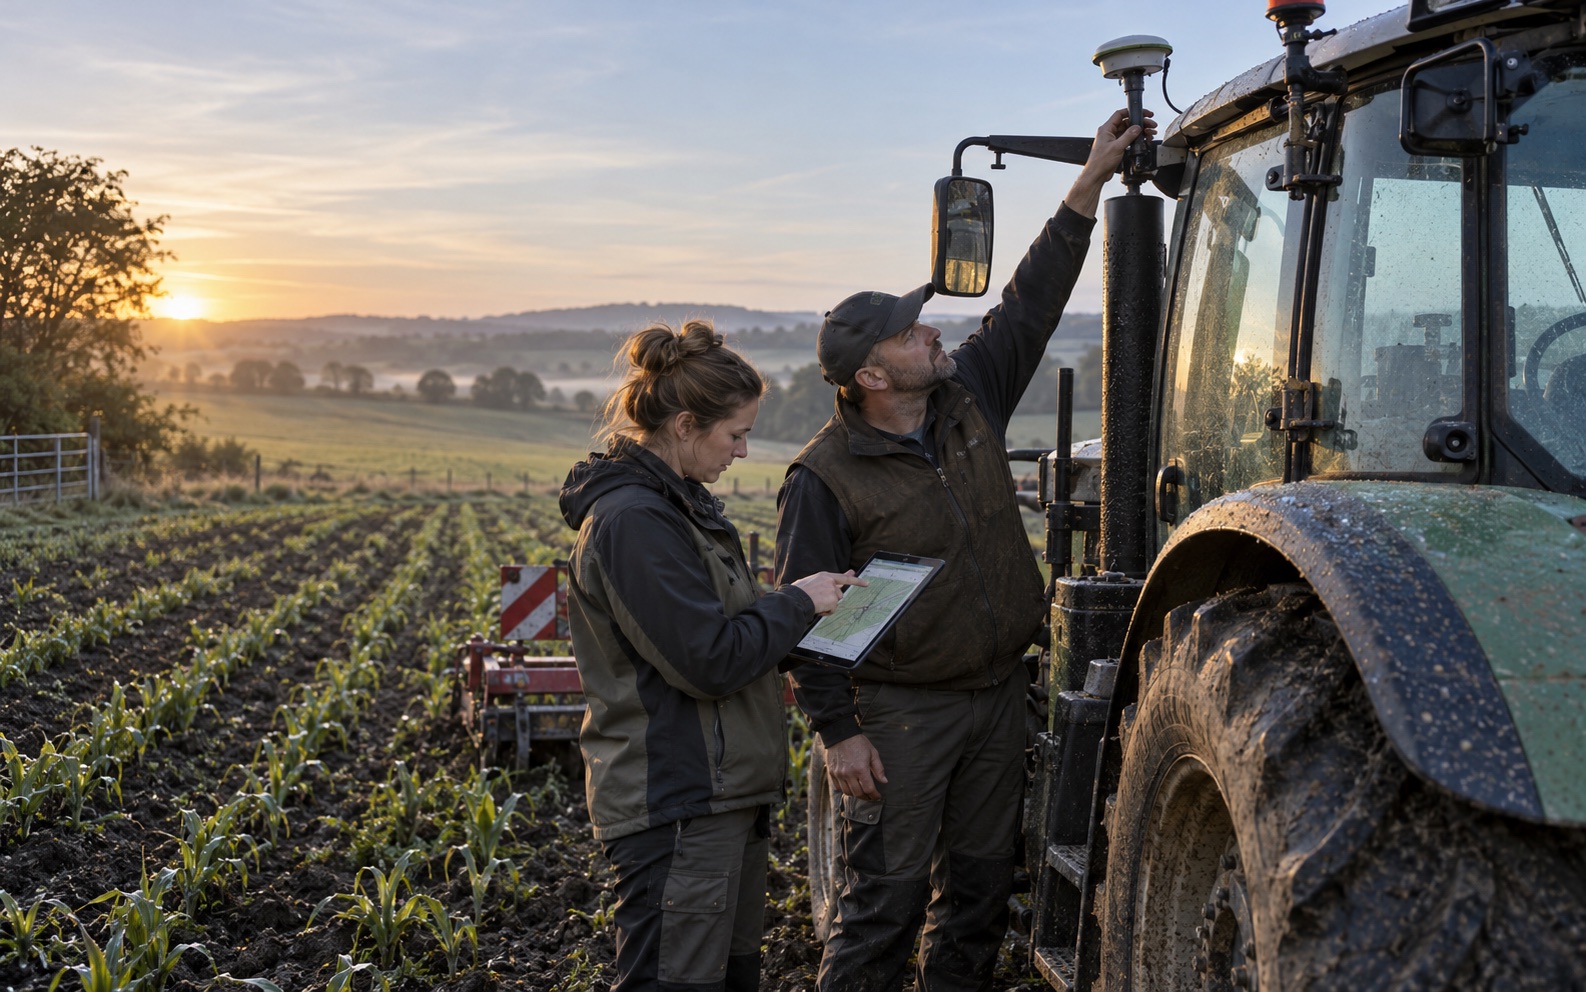
- RTK receiver, radar and sensor selection
- Application software and operator workflow
- Machine-level safety and agronomic acceptance criteria
Questions for a similar project
- Which task states must remain visible during spraying?
- Which machine, RTK and camera data must run simultaneously?
- What should remain available when field connectivity is interrupted?
Evidence boundary
Based on a company-published application story. Volume, cost and field-performance claims are intentionally omitted until supporting evidence is available.
Review the original company-published source